(香港技術院時空智能系統工程研究中心 新聞)
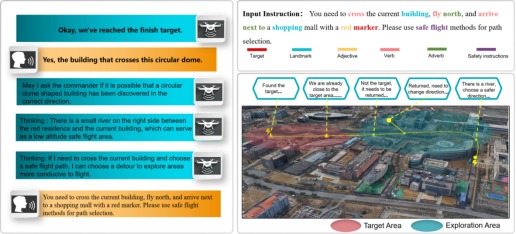
2025年12月23日,香港技術院時空智能系統工程研究中心鄂超、張斌等核心團隊成員發表研究成果《面向時空認知的探索式無人機自主視覺導航》,該論文聚焦極端環境下衛星定位信號失效、無人機易迷航撞毀,以及現有視覺-語言-導航技術遇未定義目標點易導航失敗的難題,提出無人機探索式導航系統UAV E-Nav。
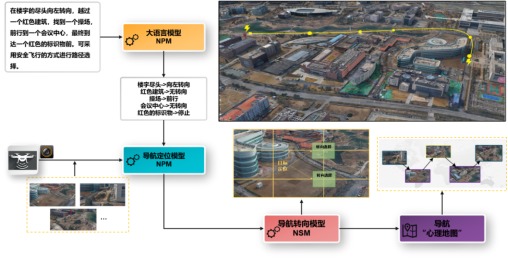
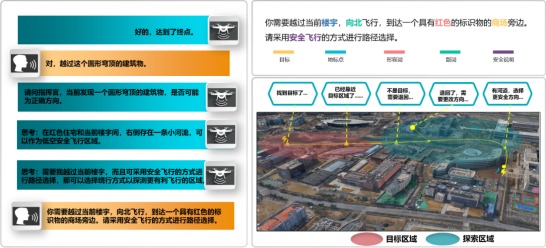
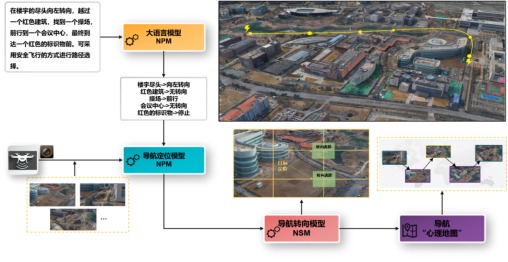
該無人機探索式導航系統UAV E-Nav,構建了大型預訓練無人機導航語言、視覺和行動模型,將高級領航員的時空認知與安全飛行經驗融入模型調優過程,實現語言、視覺與知識的跨模态融合适配。該系統由大語言模型(Large Language models,LLM)、導航定位模型 NPM(Navigation Positioning model,NPM)和導航轉向模型NSM(Navigation Steering model,NSM)構成,可從自然語言中提取地標名稱與行動副詞,透過圖像語言模型完成現實世界映射,經導航轉向模型完成下一飛行方向決策,並同步存儲於“心理地圖”中;系統無需任何微調或語言標註數據,對真實世界場景具備良好的泛化能力。基於該系統完成了真實場景無人機導航實例化驗證,在關閉衛星定位功能的條件下,透過自然語言指令成功實現了複雜戶外環境中的遠程探索式導航。本研究為無人機探索式導航提供了新的思路與範式,提升了無人機人機交互的工程實用性。
Exploratory UAV Autonomous Visual Navigation with Spatio-Temporal Cognition
On December 23, 2025, core team members including Chao E and Bin Zhang from the Research Center for Spatio-Temporal Intelligent Systems Engineering of the Hong Kong Academy of Technology published the research paper Exploratory UAV Autonomous Visual Navigation with Spatio-Temporal Cognition. Focusing on the challenges of satellite positioning signal failure in extreme environments (which causes UAVs to easily get lost and crash) and the common navigation failure of existing vision-language-navigation technologies when encountering undefined target points, the paper proposes the UAV exploratory navigation system UAV E-Nav.
The UAV exploratory navigation system UAV E-Nav constructs a large pre-trained UAV navigation language-vision-action model, integrating the spatio-temporal cognition and safe flight experience of senior navigators into the model tuning process to achieve cross-modal fusion and adaptation of language, vision, and knowledge. The system comprises three core components: the Large Language Model (LLM), the Navigation Positioning Model (NPM), and the Navigation Steering Model (NSM). It extracts landmark names and action adverbs from natural language instructions, completes real-world mapping via a vision-language model, determines the next flight direction through the navigation steering model, and synchronously stores information in a “cognitive map”. Requiring no additional fine-tuning or language annotation data, the system demonstrates strong generalization capability in real-world scenarios.
Instance verification of UAV navigation based on this system has been completed. With satellite positioning fully disabled, the system successfully realized long-distance exploratory navigation in complex outdoor environments using only natural language instructions. This research provides new ideas and paradigms for UAV exploratory navigation, and improves the engineering practicality of human-UAV interaction.